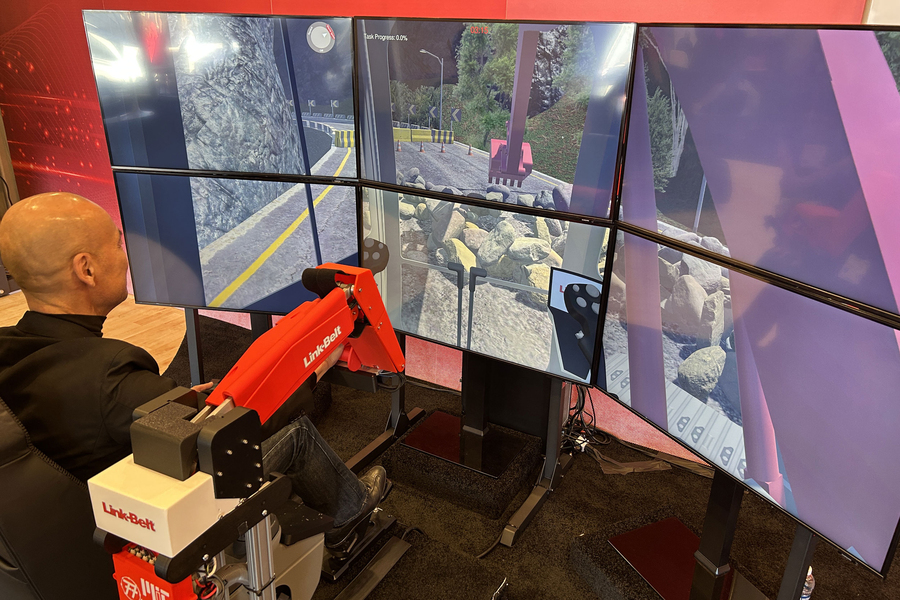
MIT engineers have developed a new excavator control system designed to reduce the time required to train heavy-equipment operators. Instead of conventional joysticks, the World-Space Interface, or WSI, uses a mechanical controller resembling a miniature excavator arm and bucket. Operators move their own arms and hands, and a virtual excavator reproduces those movements, tells MIT News.
Traditional excavators require operators to coordinate joysticks controlling the boom, arm, bucket, and cab. Learning to translate joystick movements into machine actions creates a complicated mental mapping process that can take months or years to master. MIT researchers, working with Sumitomo Heavy Industries, designed the WSI to remove much of this mental translation.
The system combines the physical controller with an immersive six-screen virtual environment. Researchers created 15 realistic settings, including construction sites, highways, mines, riverbanks, and forest roads. Participants practiced tasks such as digging trenches, grading surfaces, moving gravel, clearing debris, and breaking rocks.
During experiments, experts and novices trained for one hour daily over seven days using both the WSI and a traditional joystick simulator. With joysticks, novices consistently performed worse than experienced operators, although their skills improved with practice. With the WSI, however, beginners performed as well as experts from the start.
Researchers are now adding haptic feedback so operators can physically sense forces corresponding to activities such as lifting rocks. This could make the interface even more intuitive.
Beyond training, the technology could eventually control real excavators. Operators might use the mechanical arm inside a cab or remotely operate machinery from a safer location. Such capability could be particularly valuable at hazardous construction, mining, or disaster-response sites while helping the industry train new operators more quickly.
