Artificial intelligence (AI) is accelerating advances in robotics, but sophisticated algorithms alone cannot guarantee reliable industrial automation. Engineers must understand the physical capabilities, limitations, and behavior of robots to translate AI-driven intelligence into practical manufacturing applications, tells Design News.
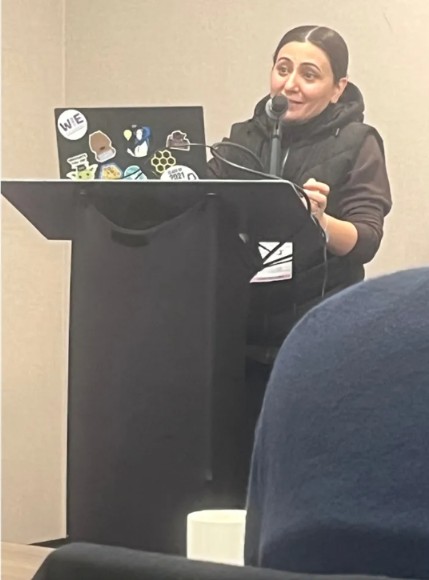
At ADM Montréal 2026, independent robotics researcher Dr. Ilknur Umay, formerly of Kuka Robotics, discussed the challenges of transforming physical AI into dependable industrial autonomy. Her presentation emphasized the gap between impressive robotic demonstrations and systems capable of operating consistently in production environments.
Although robots are learning increasingly complex tasks, factories often struggle to deploy these capabilities reliably. Real-world conditions introduce uncertainties involving material stiffness, object handling, visual interpretation, and physical contact. Fragile grasps, unexpected part movements, and ambiguous sensor information can disrupt operations, even when AI models correctly interpret their surroundings.
Umay emphasized that reliable robotic behavior requires more than visual recognition and language-based reasoning. Robots also need accurate force information, appropriate task instructions, and an understanding of physical constraints.
A robot may perform individual repetitive tasks successfully but struggle when circumstances change or additional decisions become necessary. Addressing these limitations requires connecting high-level reasoning with executable physical actions.
Umay advocates an integrated approach that combines symbolic task planning with spatial awareness and robot-specific constraints. Such systems must continuously monitor execution, process feedback, and adjust their actions when unexpected conditions arise.
For example, when a component behaves differently than expected or a safety concern emerges, the robot should identify an alternative action that remains physically feasible and safe.
Execution monitoring, feedback mechanisms, and recovery strategies therefore become essential elements of industrial autonomy. These capabilities help robots respond to changing conditions rather than simply following predetermined instructions.
As factories accelerate automation, Umay argues that engineering teams must prioritize dependable operation over demonstrations of AI capabilities. The central challenge is developing robotic systems that can consistently translate intelligent decisions into safe, repeatable physical actions.
