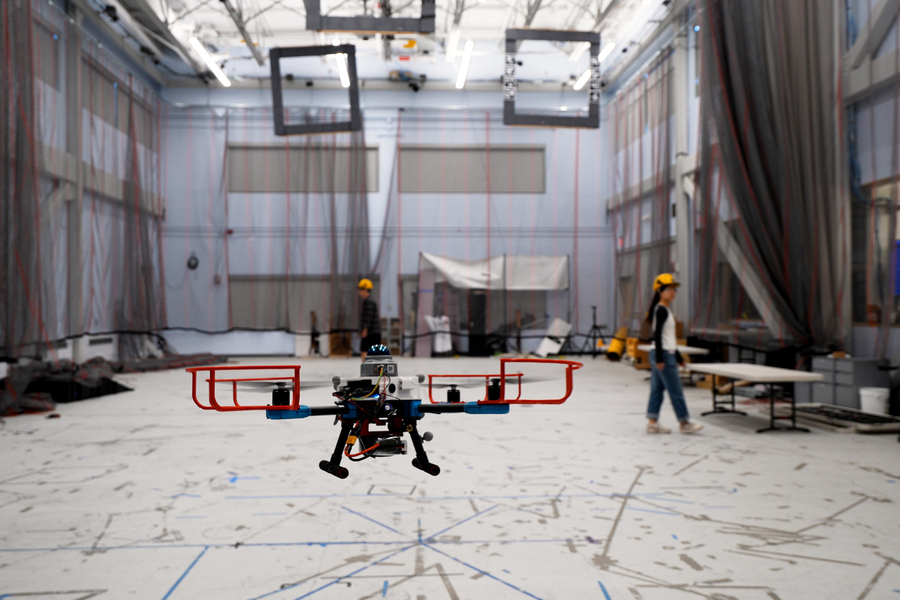
MIT researchers have developed an autonomous trajectory-planning system that enables uncrewed aerial vehicles to navigate unknown, dynamic environments while providing a mathematical guarantee that their flight paths will remain collision-free. Called SANDO, short for Safe AutoNomous trajectory planning for Dynamic unknOwn environments, the system could support drones used in disaster response, search and rescue, mine exploration, and package delivery, tells MIT News.
Existing trajectory planners often provide formal safety guarantees only when surroundings are static, or obstacles are known beforehand. SANDO addresses the harder problem of navigating an unmapped environment containing objects that may move unpredictably.
The system begins by constructing a safety corridor consisting of connected regions of three-dimensional space where the UAV can travel without encountering obstacles. SANDO adds a time component to this corridor so it can account for future obstacle movement.
Rather than predicting an obstacle’s exact trajectory, the system needs to know its maximum possible speed. It calculates how far the object could move within a given period and creates a protective sphere representing that potential movement. The UAV’s safety corridor is then planned around these regions.
SANDO also uses a heat-map-based planner to identify areas containing many obstacles and steer the UAV away from them. Once a safe corridor is established, trajectory optimization finds a fast route toward the destination. The system continually updates the corridor and replans onboard as conditions change.
In simulations, SANDO reached destinations faster than several advanced planning systems while avoiding every collision. It also avoided dynamic obstacles during 12 real-world UAV test flights.
Future research will focus on improving computational efficiency. The researchers also envision combining SANDO with machine-learning models that could let users instruct robots using natural language, adding AI-based interaction to its mathematically grounded navigation framework.
